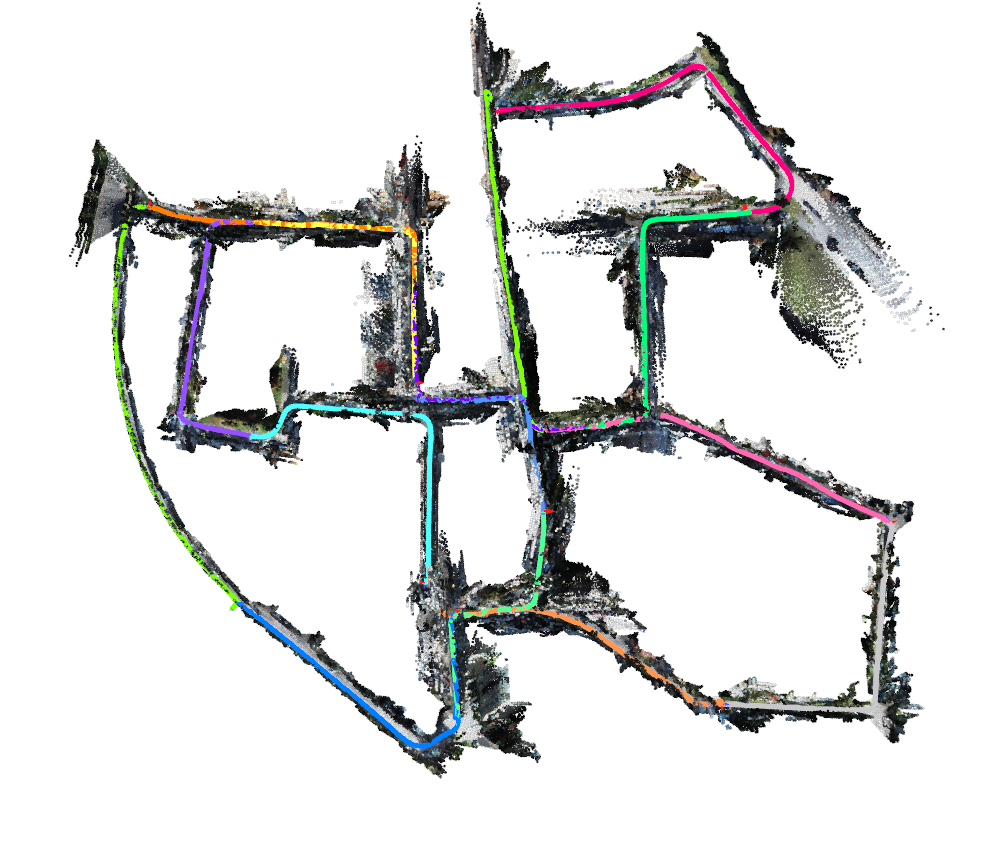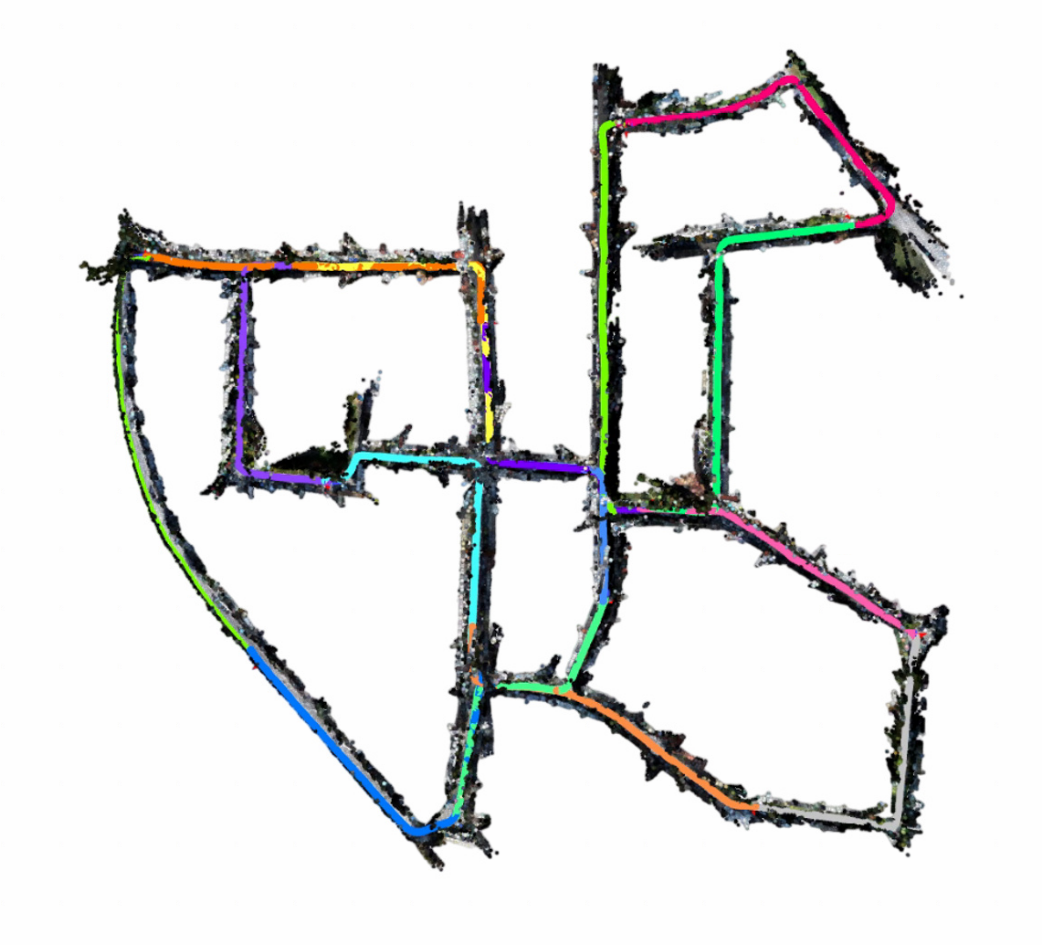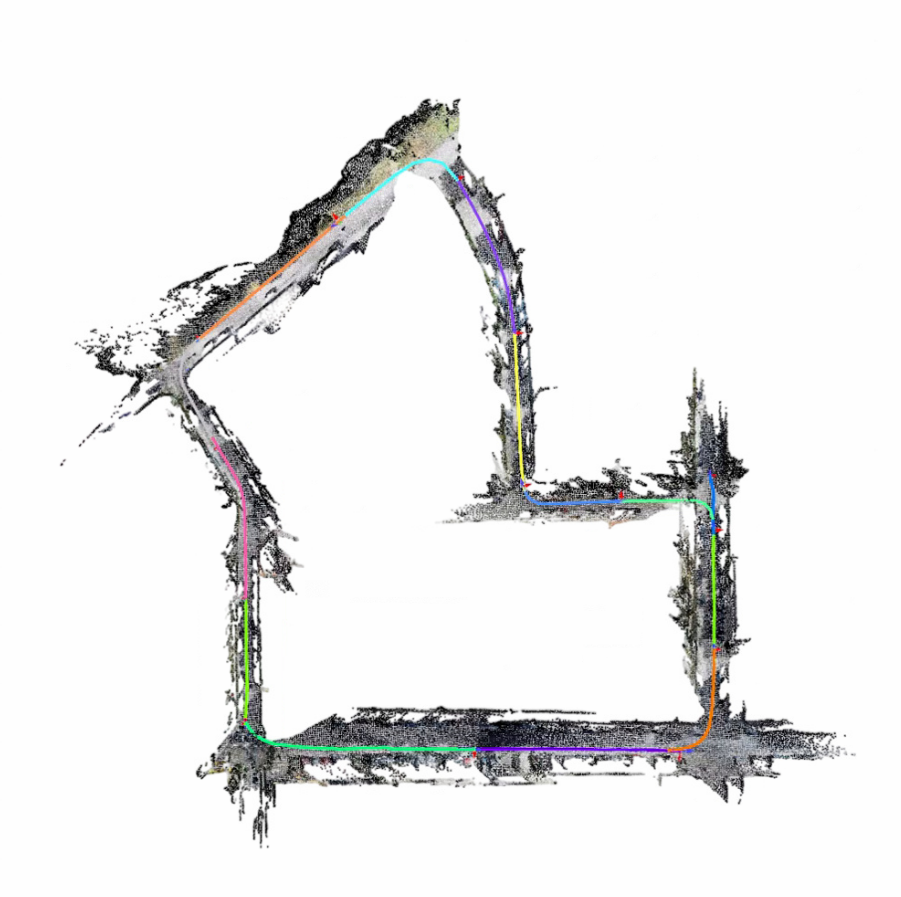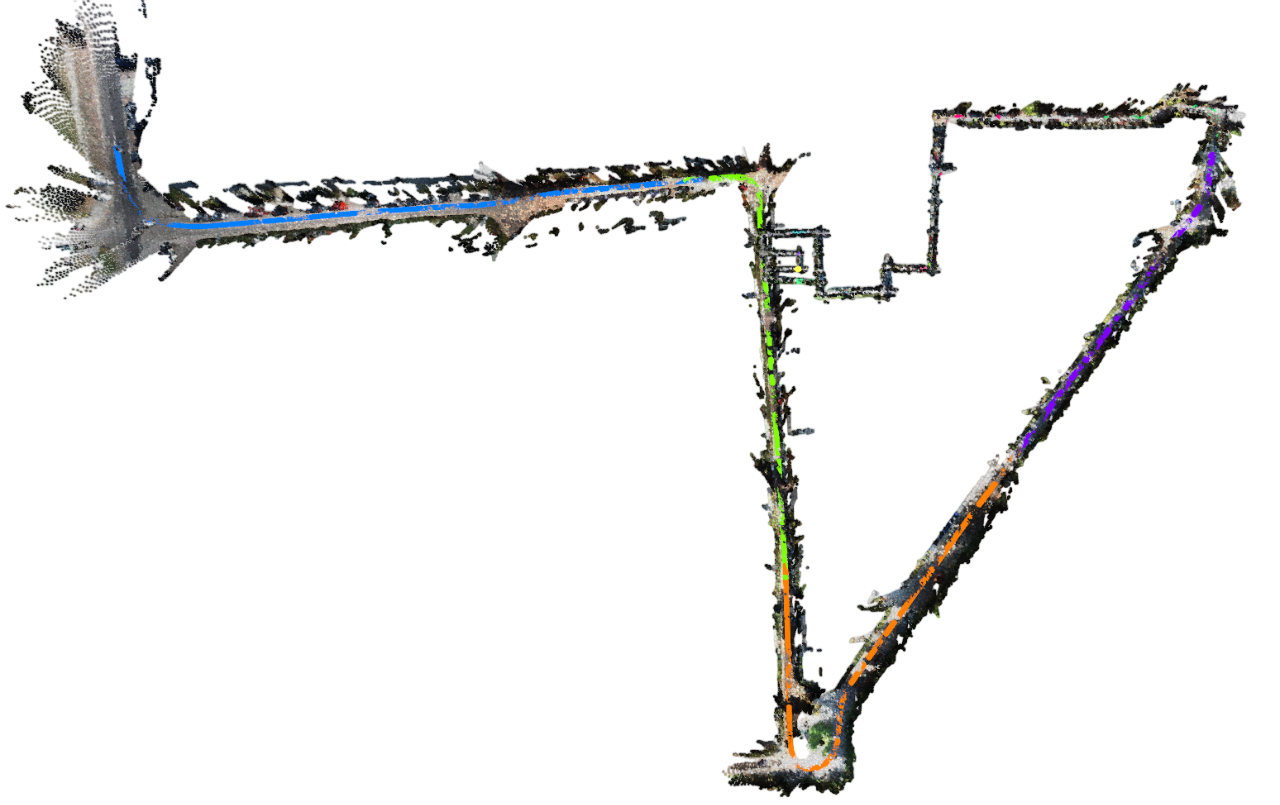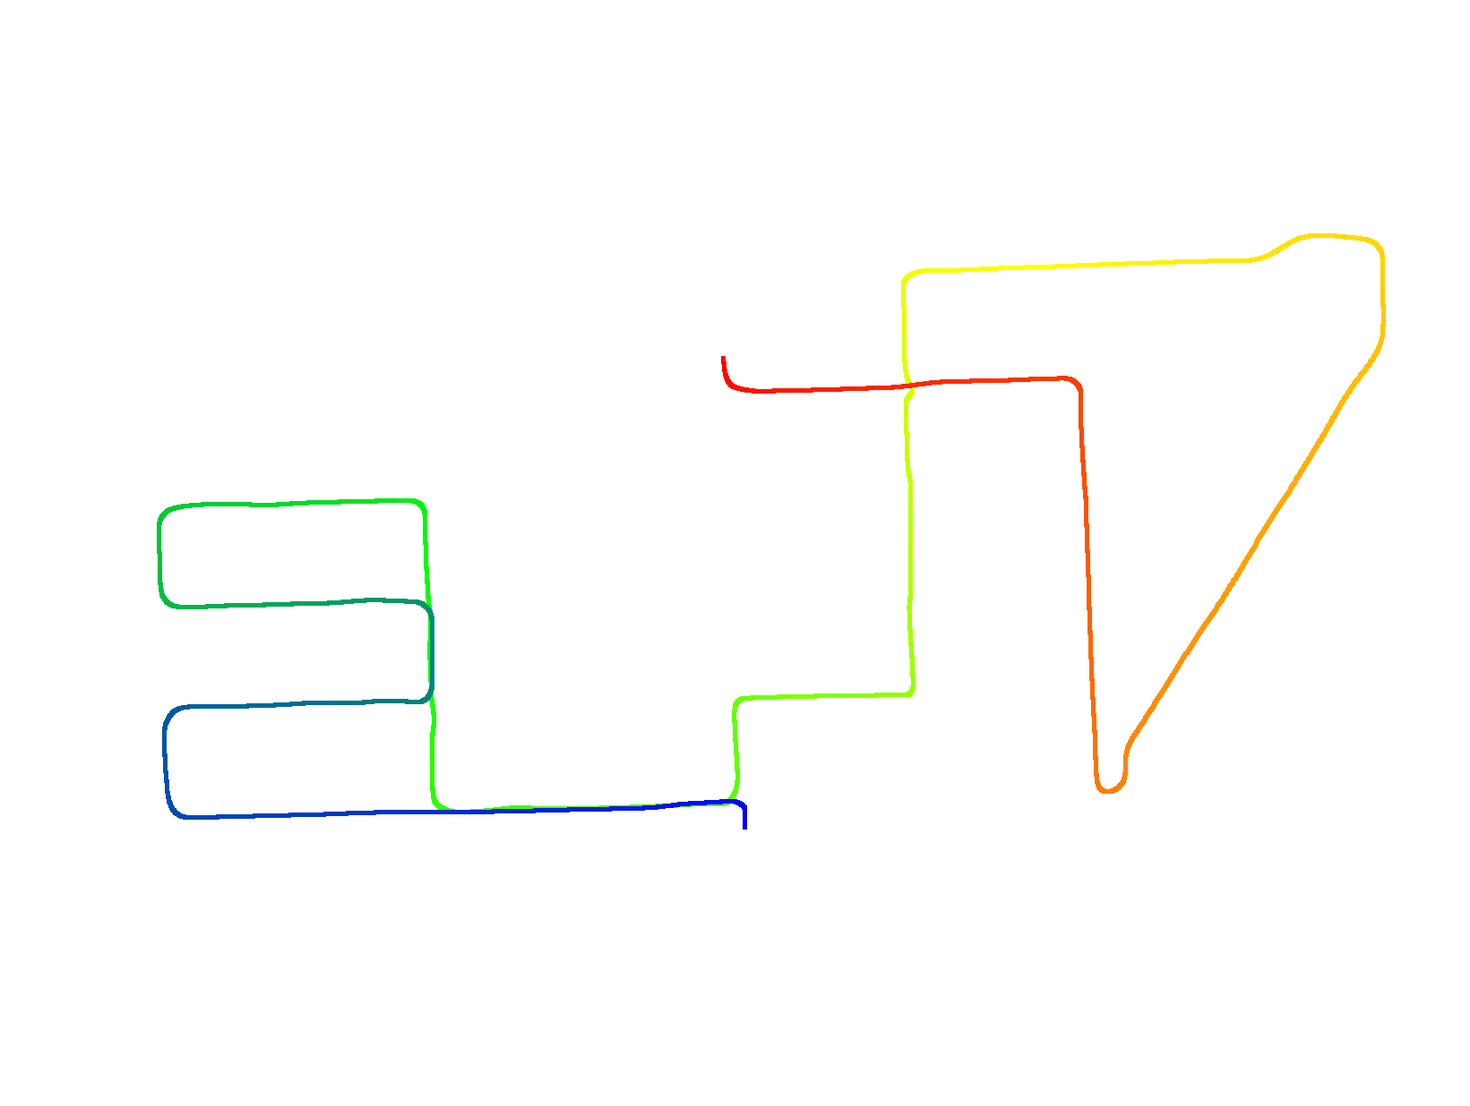
MR.ScaleMaster

Scale-Consistent Collaborative Mapping
from Crowd-Sourced Monocular Videos

Go2 (Legged Robot)
Scout Mini (Wheeled Robot)
Human #1
Human #2
scroll
Teaser

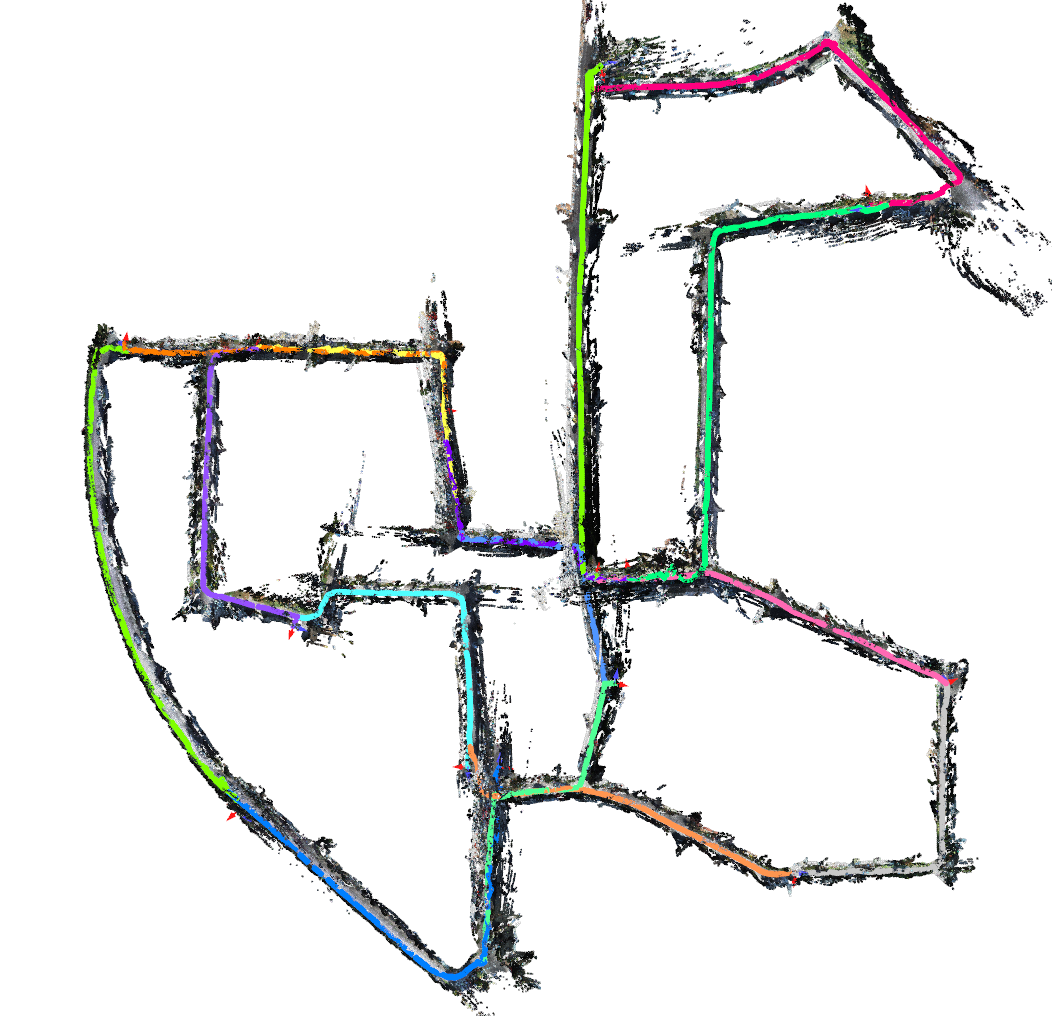
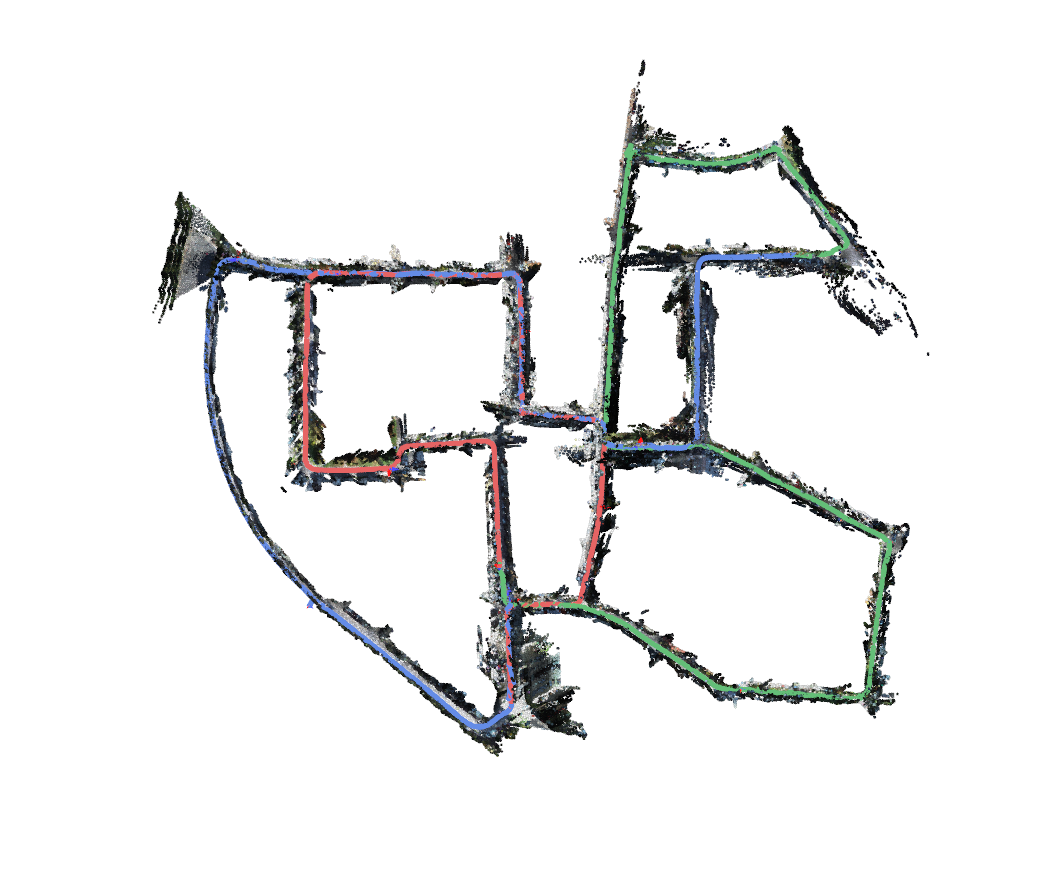
Fig. 1. Real-world heterogeneous multi-robot mapping with MR.ScaleMaster in a multi-floor indoor environment. Four agents — a legged robot ●, a wheeled robot ●, and two handheld cameras ●● — collaboratively build a unified dense 3D map. Inset pairs show inter-agent loop closures across different platforms.
Abstract

Crowd-sourced cooperative mapping from monocular cameras promises scalable 3D reconstruction without specialized sensors, yet remains hindered by two scale-specific failure modes: abrupt scale collapse from false-positive loop closures in repetitive environments, and gradual scale drift over long trajectories and per-robot scale ambiguity that prevent direct multi-session fusion. We present MR.ScaleMaster, a cooperative mapping system that addresses both failure modes through three key mechanisms. A Scale Collapse Alarm rejects spurious loop closures before they corrupt the pose graph. A Sim(3) anchor node formulation generalizes the classical SE(3) framework to explicitly estimate per-session scale, resolving per-robot scale ambiguity and enforcing global scale consistency. A modular, open-source, plug-and-play interface enables any monocular reconstruction model to integrate without backend modification. On KITTI sequences with up to 15 agents, the Sim(3) formulation achieves a 7.2× ATE reduction over the SE(3) baseline, and the alarm rejects all false-positive loops while preserving every valid constraint. We further demonstrate heterogeneous multi-robot dense mapping fusing MASt3R-SLAM, π³, and VGGT-SLAM 2.0 within a single unified map.

What Stops Monocular Collaborative Mapping?

⚡
Challenge 1
Abrupt Scale Collapse
False-positive loop closures in repetitive environments (e.g., corridors) force the optimizer to satisfy conflicting constraints by collapsing scale toward zero — or exploding it to infinity. A single erroneous factor poisons the entire pose graph.
→ Scale Collapse Alarm
📏
Challenge 2
Gradual Drift & Inter-Session Scale Mismatch
Scale estimation error accumulates over long trajectories. In multi-robot settings, each agent carries its own unknown scale factor, making direct fusion infeasible without explicit scale alignment across sessions.
→ Sim(3) Anchor Node Optimization
🔌
Challenge 3
Heterogeneous Front-End Integration
The rapidly growing ecosystem of 3D vision foundation models (MASt3R-SLAM, π³, VGGT-SLAM 2.0) each have different scale conventions, making plug-and-play multi-robot deployment difficult without a unified backend.
→ Front-End-Agnostic Modular Architecture

System Overview

System pipeline

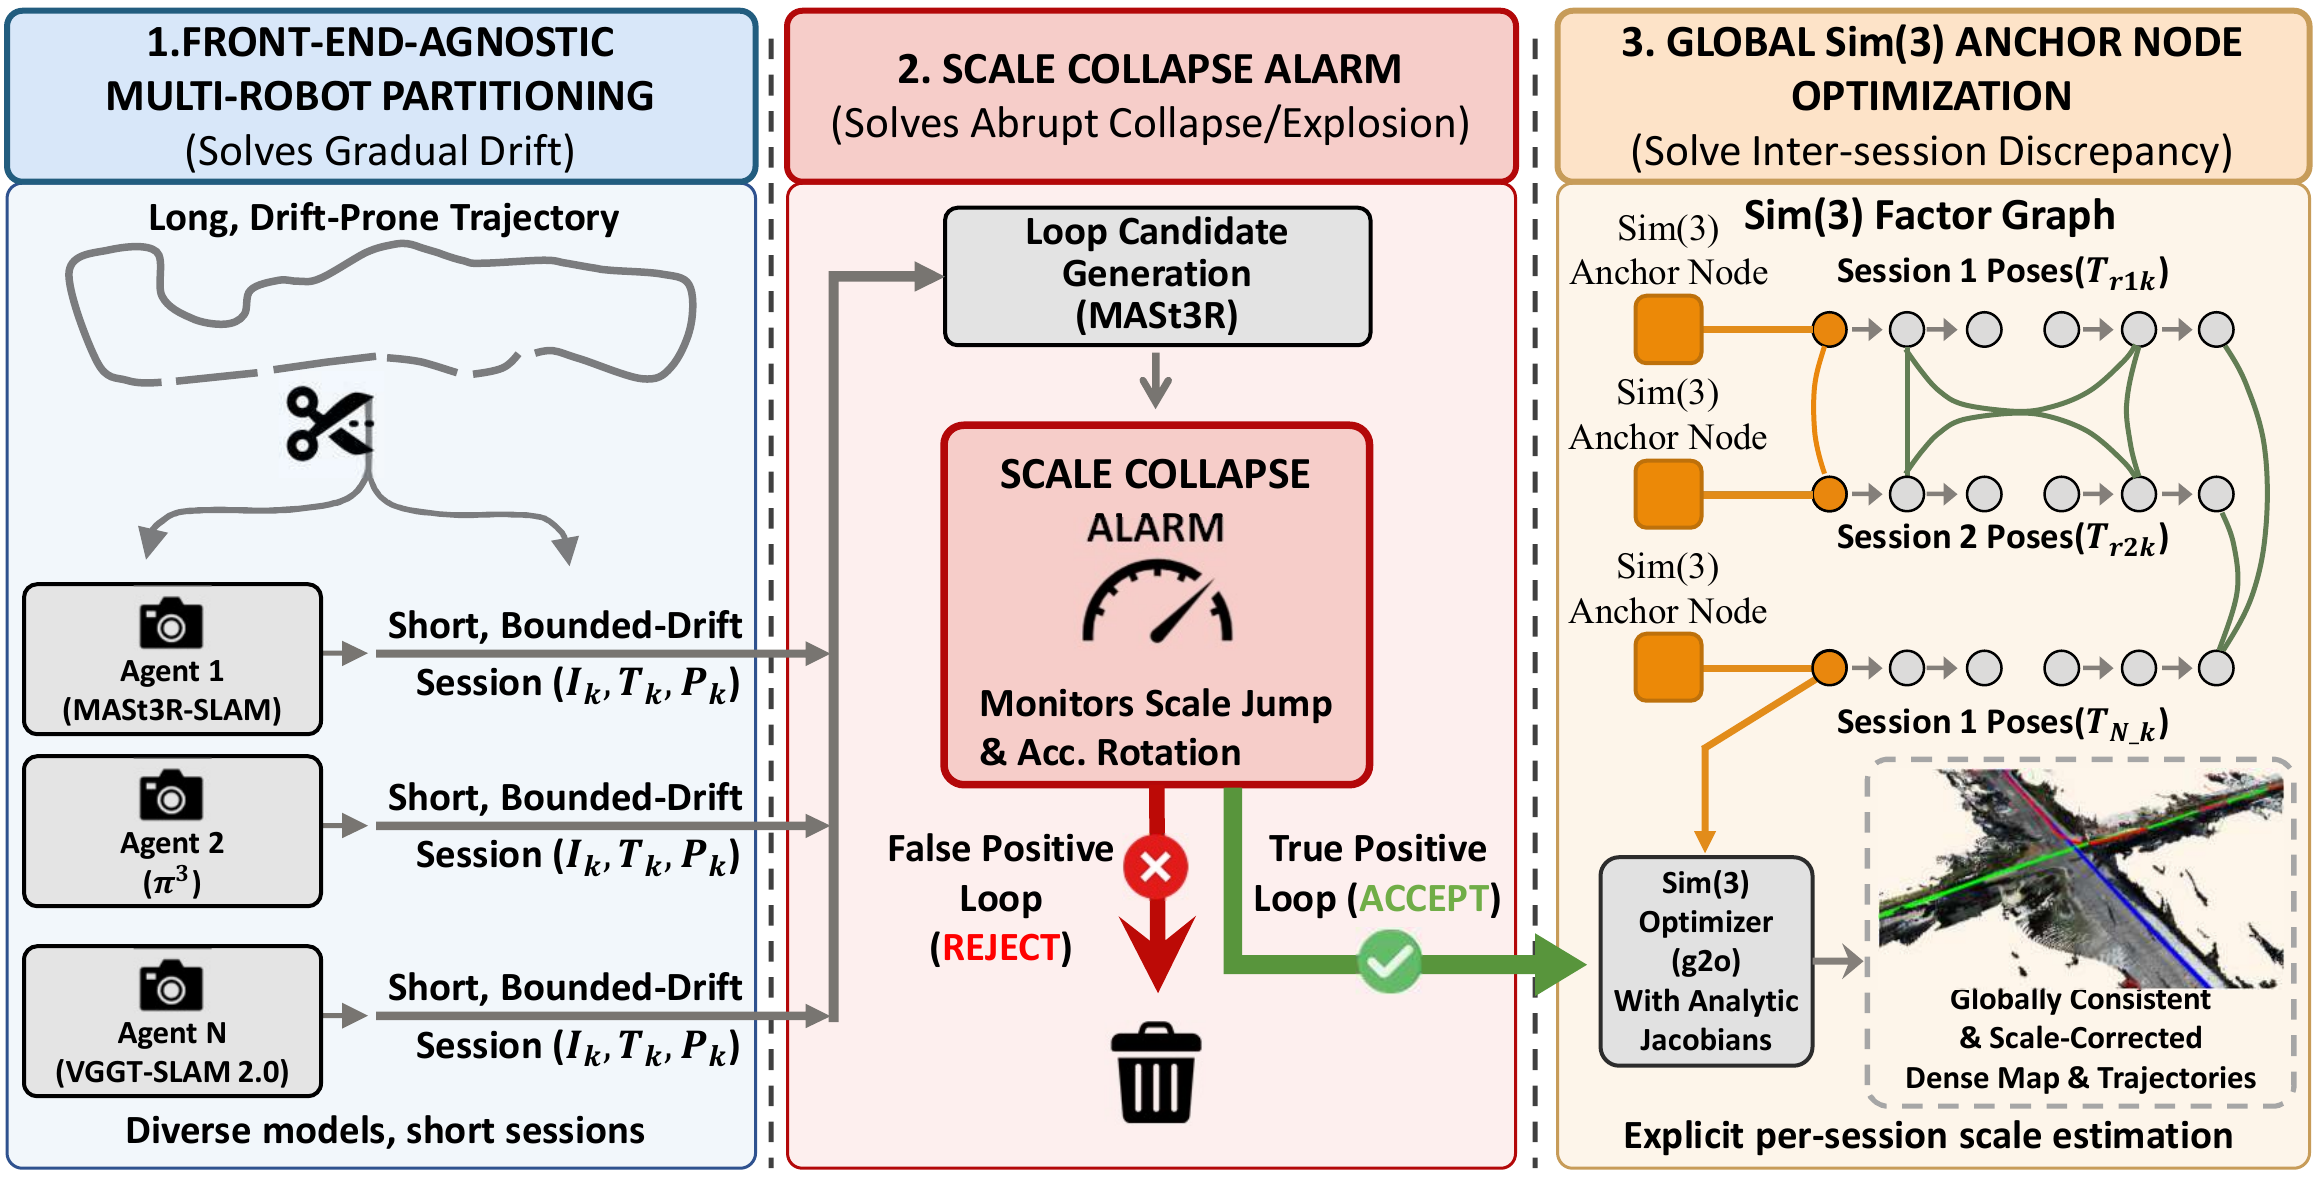
Fig. 2. System overview of MR.ScaleMaster. (1) Front-end-agnostic multi-robot partitioning bounds gradual scale drift by distributing a long trajectory across short per-agent sessions. (2) The Scale Collapse Alarm monitors per-session scale evolution and rejects false-positive loop closures before they enter the pose graph. (3) Global Sim(3) anchor node optimization resolves inter-session scale discrepancies, producing a unified dense map.

1
Front-End-Agnostic Partitioning
Each agent runs any monocular front-end (MASt3R-SLAM, π³, VGGT-SLAM 2.0) and transmits keyframe packets (Ik, Tk, Pk). Shorter per-session trajectories bound drift accumulation.
2
Scale Collapse Alarm
A two-criterion alarm — accumulated rotation check and adaptive scale-jump detection — gates degenerate loop factors before they enter the pose graph, with transactional rollback on detection.
3
Global Sim(3) Anchor Optimization
Sim(3) anchor nodes map each session's local frame into a shared global frame. Per-session scale is an explicit degree of freedom, resolved jointly across all inter-session loop constraints via g2o with analytic Jacobians.

Scale Collapse Alarm — Before & After

Exp 1 — Corridor

Before After

Exp 2 — Perceptually Aliased Corridor

Before After

Sim(3) Anchor Node Optimization — Visualization

Qualitative Results

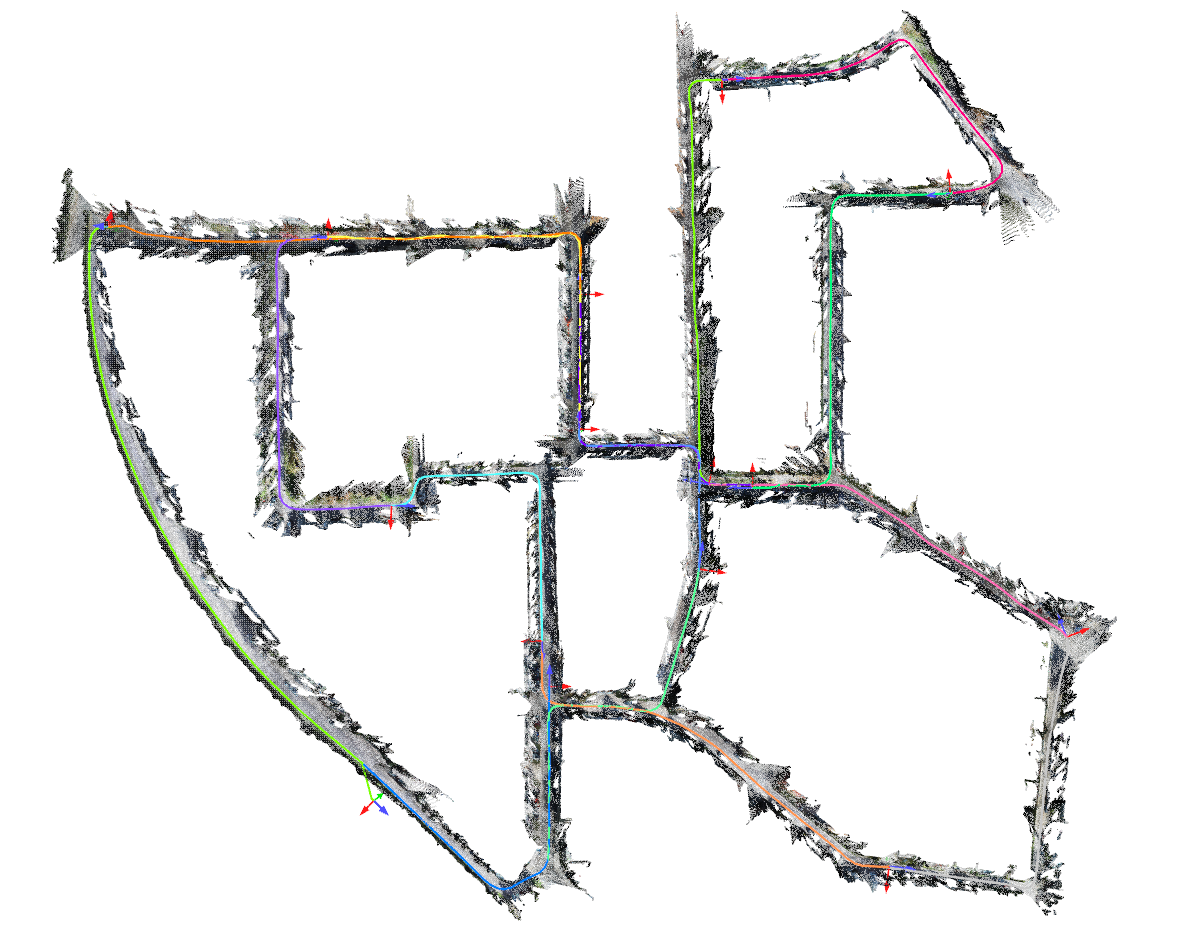
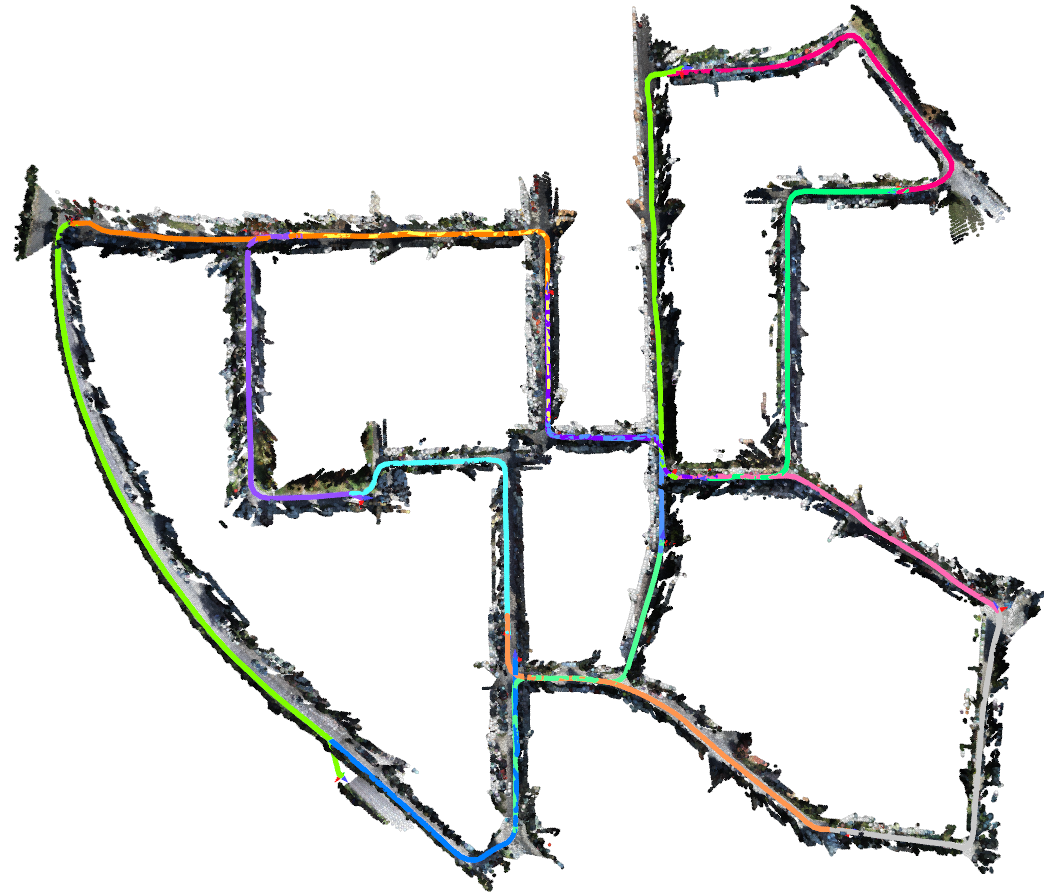
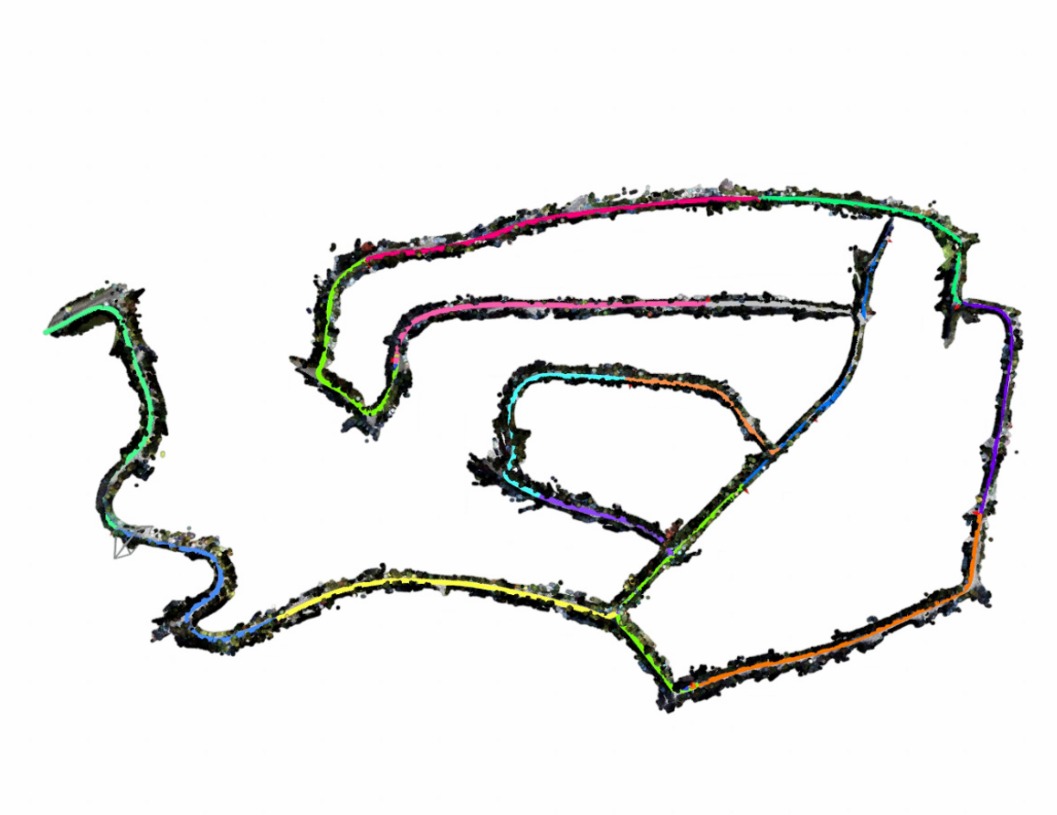
Fig. 4. Effect of scale estimation on KITTI 00 with 15 robots. Ours jointly refines anchor nodes and keyframe poses, yielding globally consistent trajectories.

Heterogeneous Front-End Deployment

KITTI 00 · 15 robots · The same backend handles all front-ends without modification.

Fig. 7. Front-end agnostic validation on KITTI 00 with 15 robots. The heterogeneous deployment (18.74 m) outperforms homogeneous π³, indicating that stronger front-ends contribute corrective constraints that benefit weaker ones.

Video Comparison

KITTI benchmark — select a sequence to compare all front-ends side by side.

MASt3R-SLAM CVPR 2025
VGGT-SLAM 2.0 arXiv 2026
Heterogeneous
MASt3R-SLAM CVPR 2025
VGGT-SLAM 2.0 arXiv 2026
Heterogeneous
MASt3R-SLAM CVPR 2025
VGGT-SLAM 2.0 arXiv 2026
Heterogeneous
MASt3R-SLAM CVPR 2025
VGGT-SLAM 2.0 arXiv 2026
Heterogeneous
MASt3R-SLAM CVPR 2025
VGGT-SLAM 2.0 arXiv 2026
Heterogeneous

Trajectory Comparison

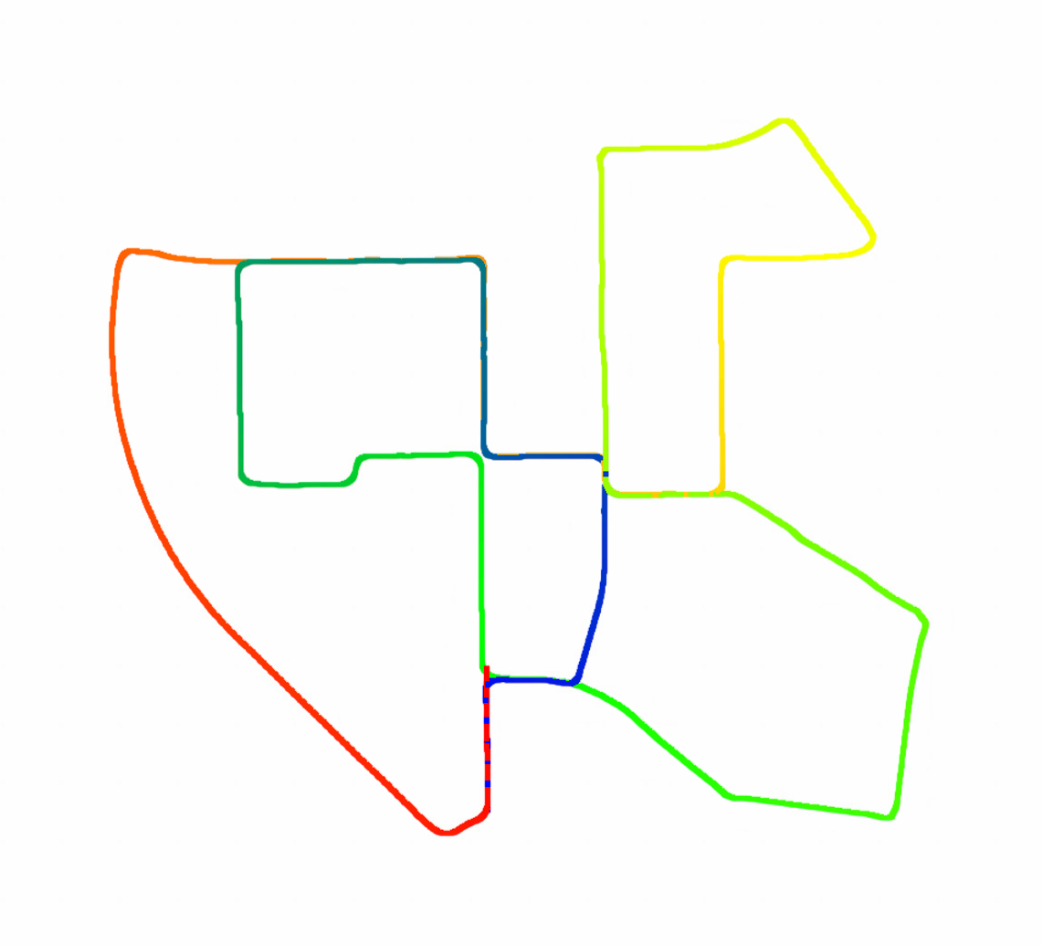
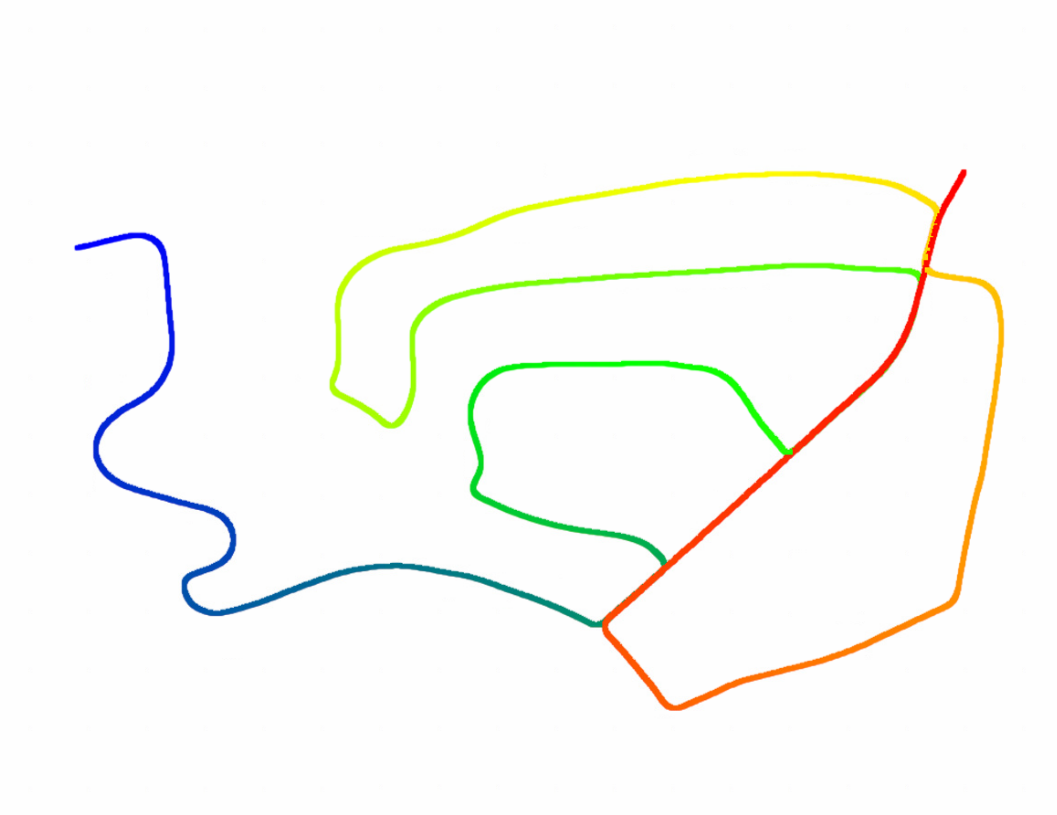
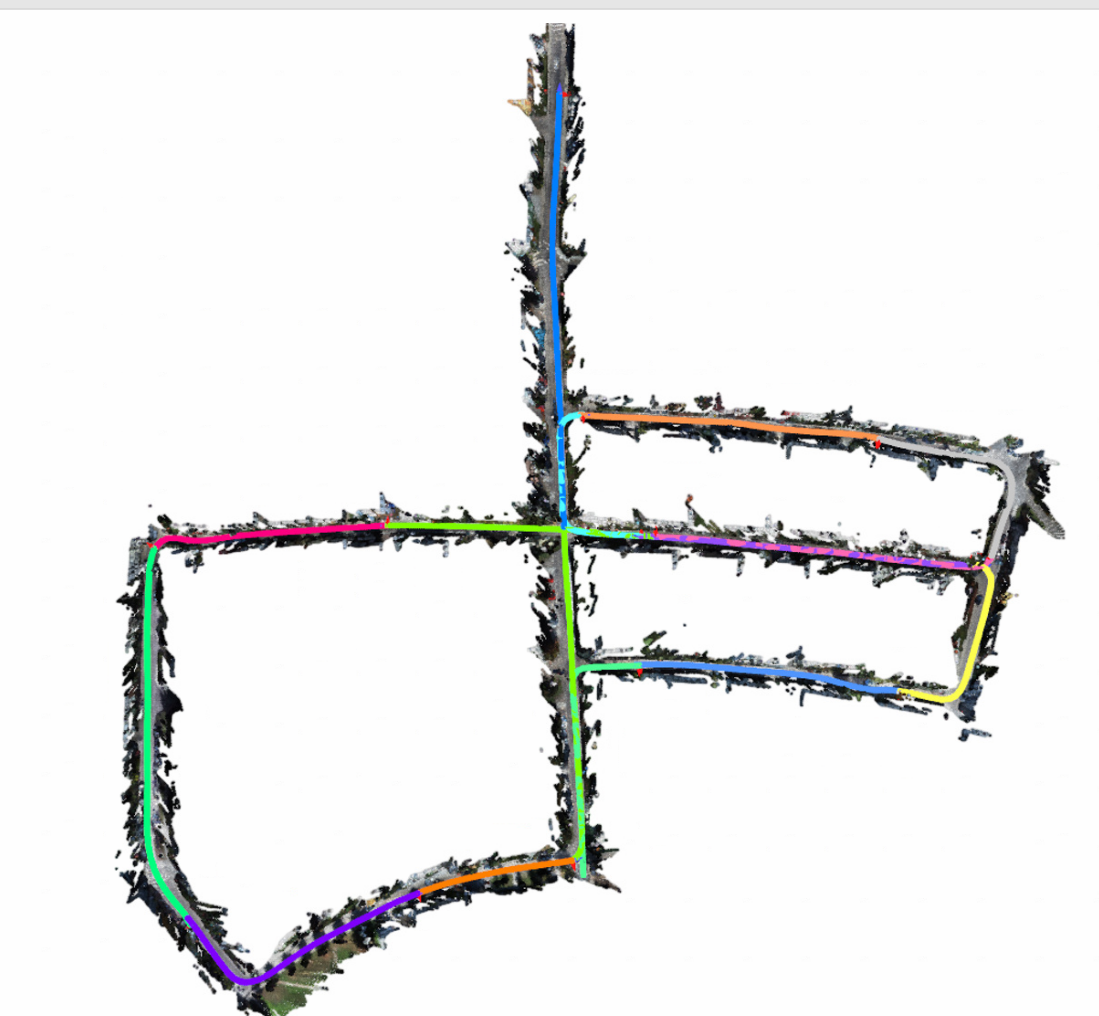
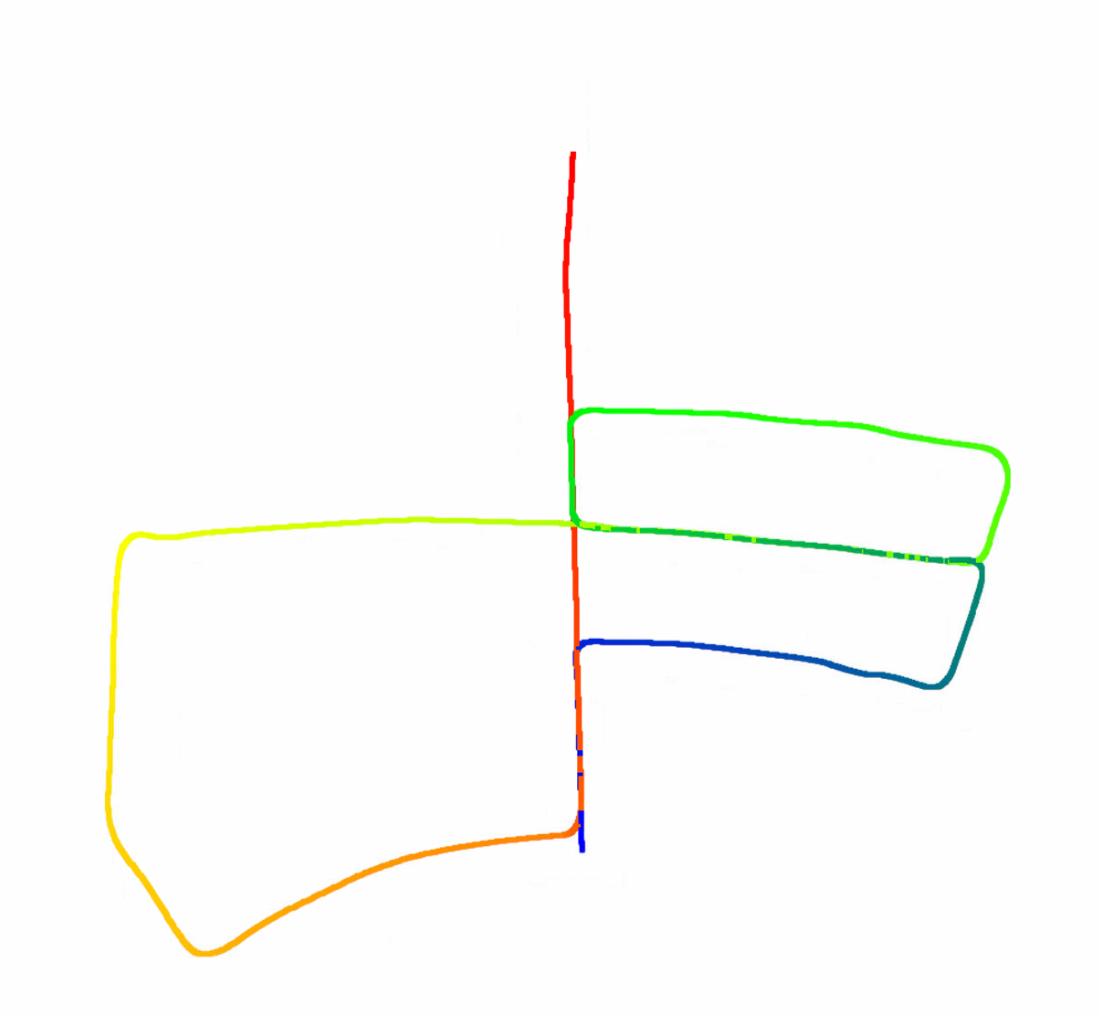
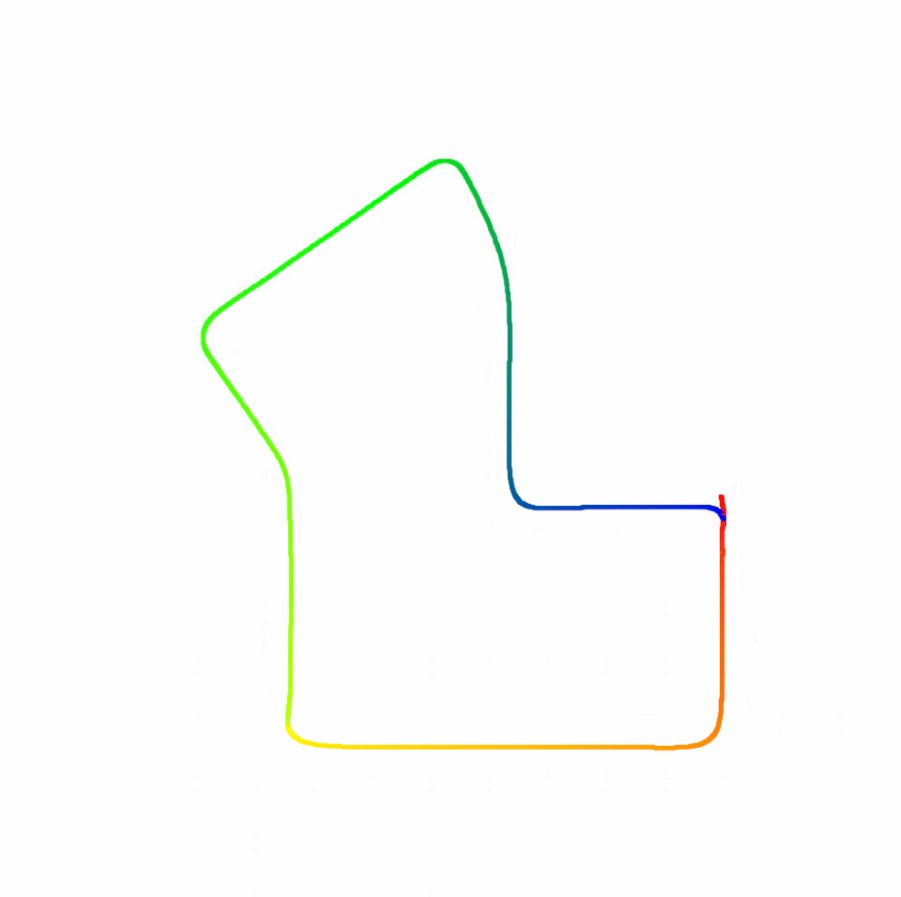
Drag the handle to compare estimated trajectory (left) vs. ground truth (right).

KITTI 00 Estimated
KITTI 00 Ground Truth
⇔
Estimated Ground Truth
KITTI 02 Estimated
KITTI 02 Ground Truth
⇔
Estimated Ground Truth
KITTI 05 Estimated
KITTI 05 Ground Truth
⇔
Estimated Ground Truth
KITTI 07 Estimated
KITTI 07 Ground Truth
⇔
Estimated Ground Truth
KITTI 08 Estimated
KITTI 08 Ground Truth
⇔
Estimated Ground Truth

Real-World Experiment

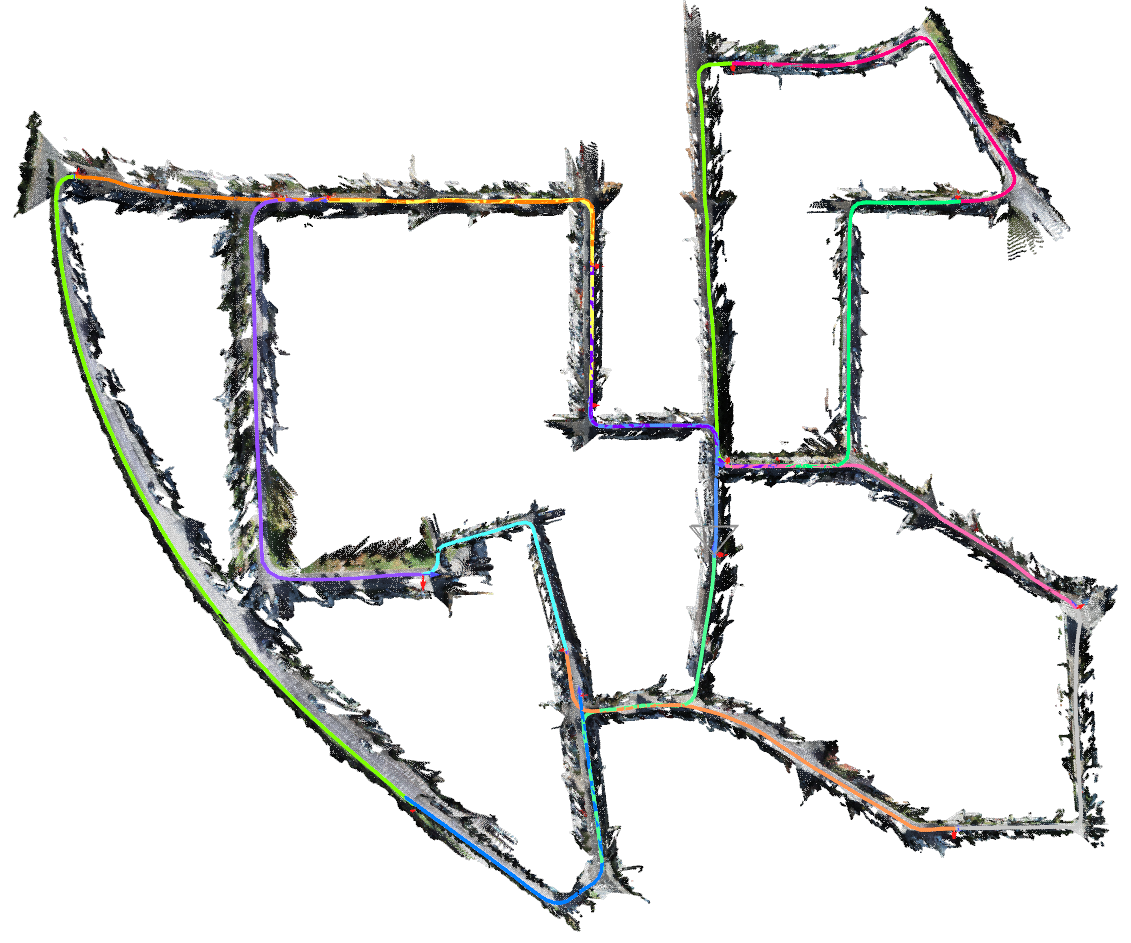
Four heterogeneous agents capture the environment independently. MR.ScaleMaster fuses their monocular streams into a single consistent 3D map.

Exp 1 — Indoor & Outdoor Multi-Agent
Go2 (Legged Robot)
Human #1
Scout Mini (Wheeled Robot)
Human #2
MR.ScaleMaster
↓
Collaborative 3D Map

Exp 2 — Indoor Library (Multi-Floor)
Collaborative 3D Map